Systems engineering
Hardware that thinks for itself.
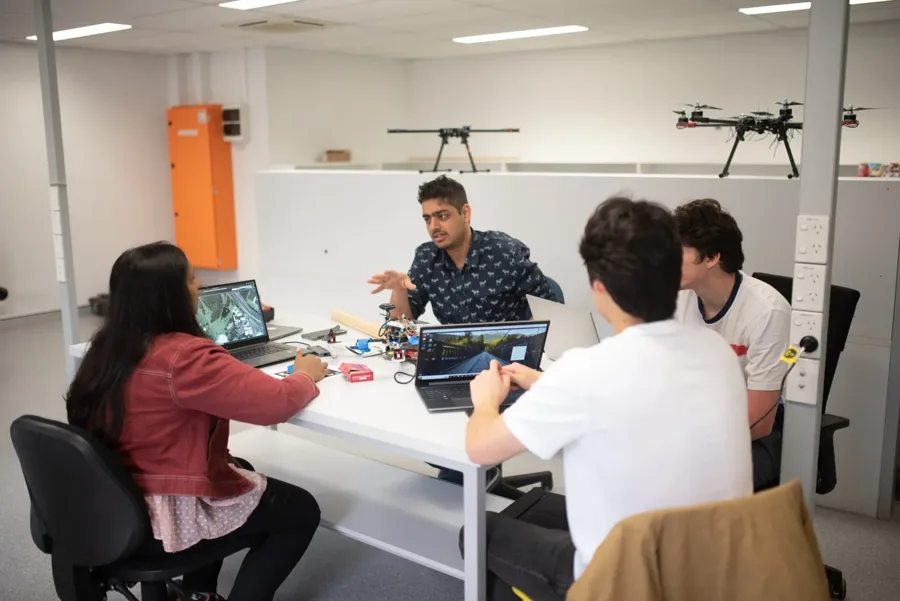
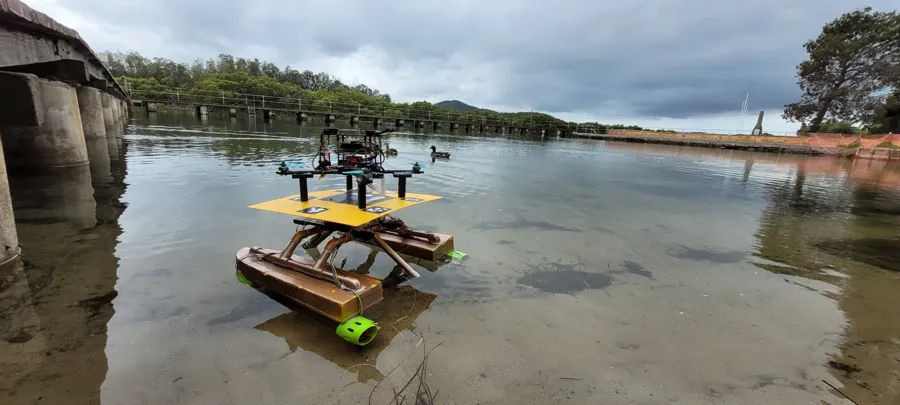
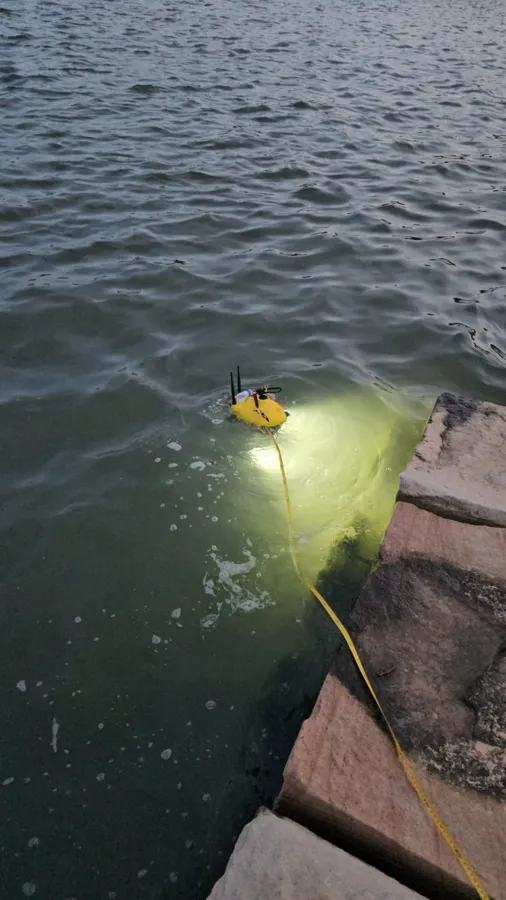
Every drone we fly starts as a stack of parts and a problem nobody has solved yet. The work is the full chain: sensors, power, embedded code, autonomy, and the ground station that talks to all of it.
- Raspberry Pi 5 and Jetson Orin on board, talking to CubePilot Orange and Pixhawk 6C
- ROS 2 on Ubuntu, PX4 and ArduPilot, MAVLink over TCP and UDP
- OptiTrack for indoor flight, GPS RTK and UWB outdoors
- STM32 and RTOS on the bench, KiCad when the board does not exist yet